Underwater Labriform-Swimming Robot
Oct 2021 · Topics in Systems Engineering Book 1 · World Scientific
Ebook
208
Pages
Tools
info
family_home
Eligible
info
About this ebook
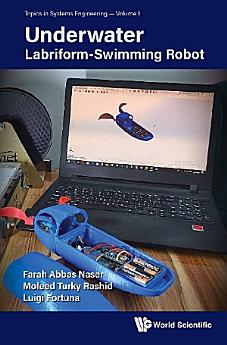
This book provides a simplified description of how to design an underwater swimming robot, inspired by the mechanism of the Labriform mode of fish. This style of swimming depends on the pectoral fins only as a main locomotor for movement. A unique model with fins having a concave shape allows the highest thrust force to be achieved during the power period and the lowest drag force during the recovery period, especially if the velocity values between the powering and recovery periods are manipulated.
Besides the ability to swim quickly, the proposed model was also inspired by a method of maneuvering based on the principle of differential drive for two-wheel mobile robot, achieving the minimum turning radius by controlling the speed of the rowing fins.
Also, by applying the technique of the diving model used by gliders, the robot achieves underwater gliding by changing the center of the body's mass. Thus, the robot obtains the ability to dive and float in a manner similar to the Sawtooth wave.
All the mentioned tasks were conducted via laboratory experiments and proven to be both effective and efficient.
This book provides a simplified description of how to design an underwater swimming robot, inspired by the mechanism of the Labriform mode of fish. This style of swimming depends on the pectoral fins only as a main locomotor for movement. A unique model with fins having a concave shape allows the...
Discover more
Rate this ebook
Tell us what you think.
Reading information
Smartphones and tablets
Install the Google Play Books app for Android and iPad/iPhone. It syncs automatically with your account and allows you to read online or offline wherever you are.
Laptops and computers
You can listen to audiobooks purchased on Google Play using your computer's web browser.
eReaders and other devices
To read on e-ink devices like Kobo eReaders, you'll need to download a file and transfer it to your device. Follow the detailed Help Center instructions to transfer the files to supported eReaders.