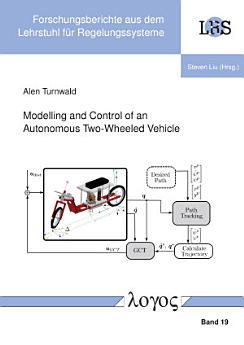
Modelling and Control of an Autonomous Two-Wheeled Vehicle

· Logos Verlag Berlin GmbH
Ebook
175
Pages
Eligible

About this ebook

With respect to the future urban mobility, modern electrical bicycles, advanced motorcycles and innovative two-wheeled vehicles are arresting enormous amount of attention. Especially, model-based control and optimal trajectory planning for such vehicles are important to the research and development of the future. Therefore, a reliable and yet usable vehicle model as well as a systematic approach to motion control for two-wheeled vehicles are essential, to which this work makes a contribution.

Currently available two-wheeled vehicle models are mostly either too complex to be used for a systematic control synthesis, or too simple such that the physical behaviour of the vehicle is no more represented. In this thesis, a unifying approach to modelling and control for autonomous two-wheeled vehicles is presented. The resulting model is generally valid and physically detailed enough to represent the characteristic dynamical behaviour such as the self-stability. At the same time, it is suited to a systematic control synthesis. Furthermore, the systematic extenddability, for instance by a rider, is demonstrated. The model is validated by simulations and by comparison to well-known models from the literature.


The proposed vehicle model is derived in the Lagrangian and Hamiltonian framework and used for model-based optimal trajectory planning. Furthermore, a passivity-based trajectory tracking controller is designed based on the resulting port-Hamiltonian system using the so-called generalised canonical transformations. Such a controller is physically interpretable and robust against parameter uncertainties. To this end, existing approaches of passivity-based controller design are extended and adjusted for two-wheeled vehicles.


Finally, a prototype two-wheeled vehicle is introduced which is used for experimental validation of the model and to demonstrate motion control algorithms for autonomous two-wheeled vehicles.
With respect to the future urban mobility, modern electrical bicycles, advanced motorcycles and innovative two-wheeled vehicles are arresting enormous amount of attention. Especially, model-based control and optimal trajectory planning for such vehicles are important to the research and developme...

Discover more

Rate this ebook

Tell us what you think.

Reading information

Smartphones and tablets
Install the Google Play Books app for Android and iPad/iPhone. It syncs automatically with your account and allows you to read online or offline wherever you are.
Laptops and computers
You can listen to audiobooks purchased on Google Play using your computer's web browser.
eReaders and other devices
To read on e-ink devices like Kobo eReaders, you'll need to download a file and transfer it to your device. Follow the detailed Help Center instructions to transfer the files to supported eReaders.